Traffic Camera Image Classification & Computer Vision
A Python vision pipeline and desktop app that scores roadway visibility, flags camera problems, and organizes review across UDOT's traffic cameras.
Outcomes
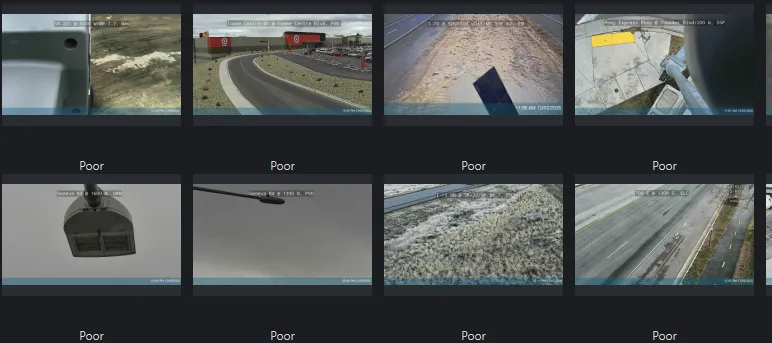
- The main label is Good View, Limited View, or Poor View, based on how useful the image is for traffic and roadway conditions.
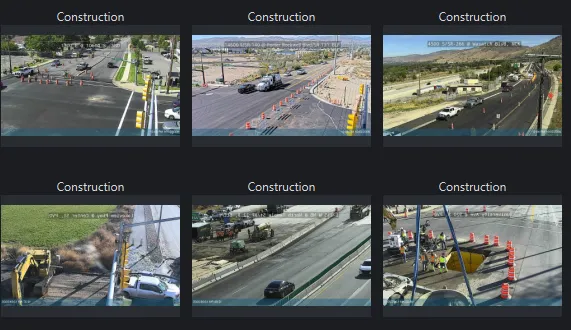
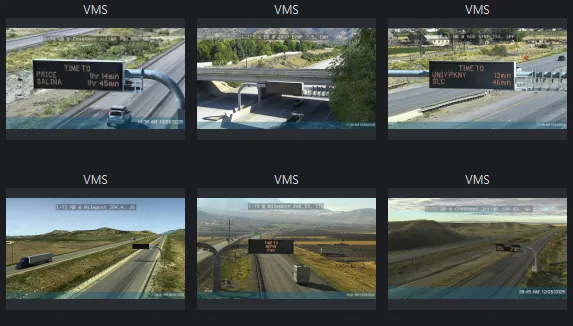
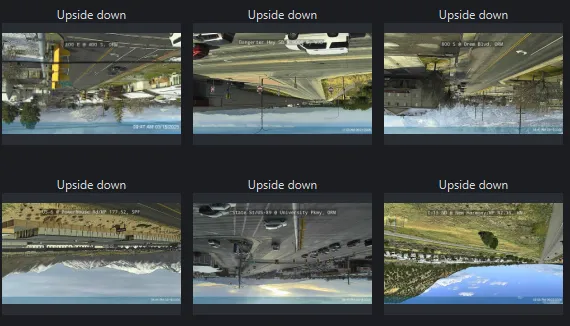
- Other tags flag rotation, power-over-Ethernet overlays, obstructions, offline placeholders, black-and-white images, frozen frames, cameras aimed at their poles, construction, message signs, and snow.
- The interface covers image collection, labeling, model training, and classification of current frames.
UDOT’s approximately 2,000 traffic cameras cover intersections, freeways, and rural highways. Angles and surroundings vary, and a working camera can still show little of the road if it points away, is blocked, or is zoomed too tight. Reviewing images one by one takes too long.
Trained classifiers assign the main label: Good View, Limited View, or Poor View, based on how useful the image is for traffic and roadway conditions. Other checks tag rotated frames, power-over-Ethernet warning overlays, obstructed lenses, offline placeholders, black-and-white images, frozen frames found from timestamps, and cameras pointed at their own poles. Separate tags mark construction, variable message signs, and snow.
A desktop interface collects images, labels datasets, trains the models, and classifies current frames. The aim is to surface cameras that need attention, for a poor view as well as a faulty image.